
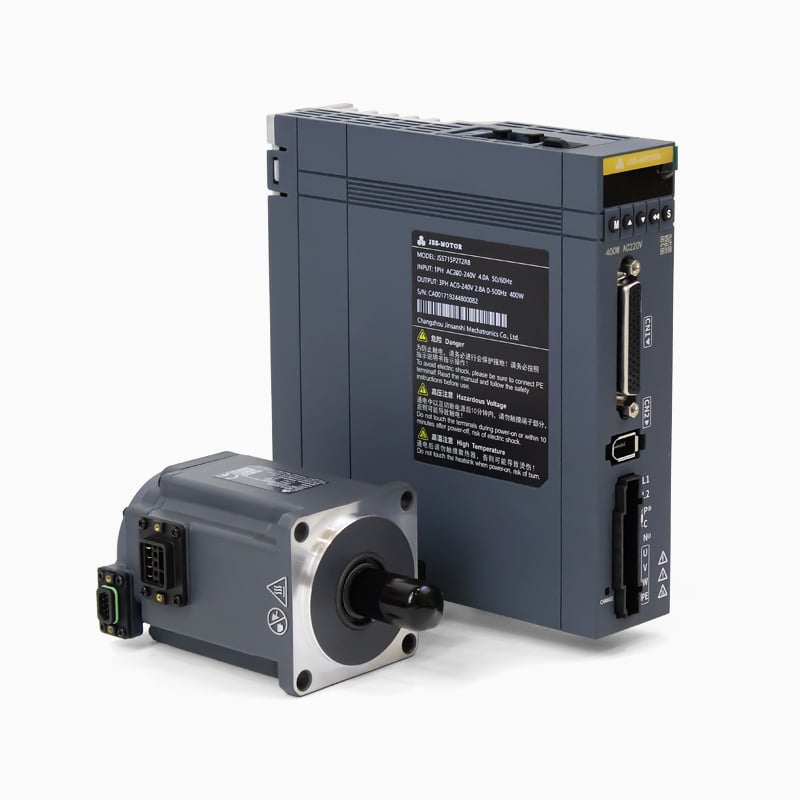
In modern industrial automation, the demand for accuracy, repeatability, and speed has never been higher. Whether it is a robotic arm assembling microelectronics, a CNC machine cutting aerospace components, or a packaging line synchronizing dozens of axes simultaneously, the underlying technology that makes precision possible is servo motors and drives. These components are not simply motors that spin — they are closed-loop systems that continuously measure, correct, and optimize motion in real time, delivering the kind of performance that open-loop alternatives simply cannot match.
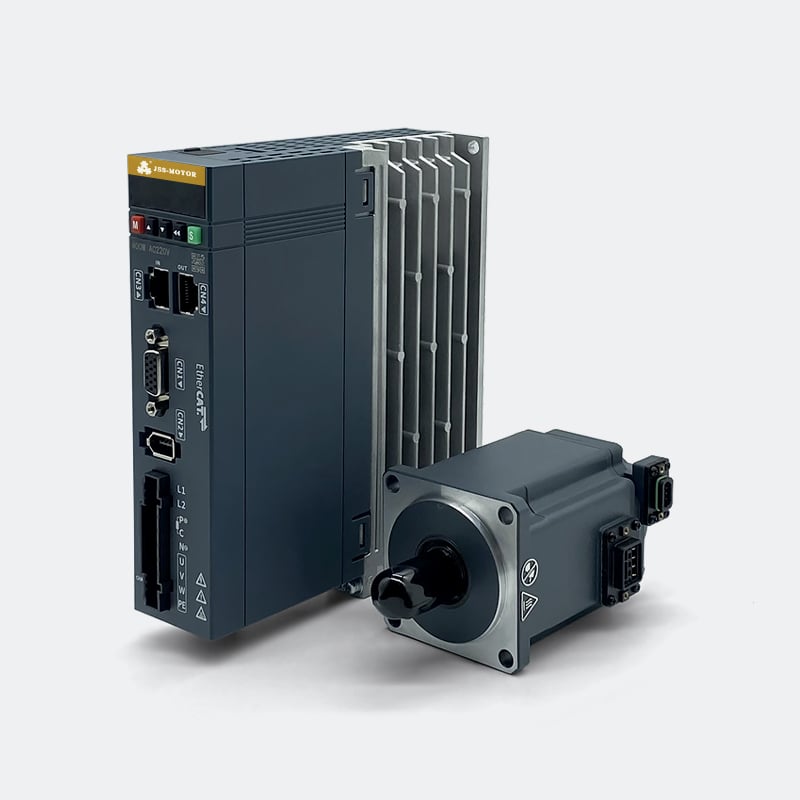
Understanding why servo motors and drives are essential to precise automation requires looking beyond their basic function. It means examining how they respond to dynamic load changes, how they integrate with modern communication protocols, and why engineers across industries consistently choose them when tolerances are tight and throughput demands are high. This article explores the core reasons these systems have become indispensable in precision-driven manufacturing and automation environments.
The Closed-Loop Advantage That Defines Precision
How Feedback Transforms Motion Control
The defining characteristic of servo motors and drives is their use of closed-loop feedback. Unlike stepper motors or standard AC induction motors, a servo system continuously monitors the actual position, velocity, and torque of the motor shaft and compares that data against the commanded values. Any deviation — no matter how small — triggers an immediate corrective response from the drive.
This feedback loop is made possible by encoders mounted directly on the motor shaft. High-resolution encoders, such as 17-bit absolute encoders, can resolve over 131,000 distinct positions per revolution. This level of granularity means the system always knows exactly where the shaft is, even after a power cycle, eliminating the need for homing routines in many applications.
The practical result is that servo motors and drives can maintain positional accuracy within fractions of a degree under varying load conditions. In applications like semiconductor wafer handling or precision dispensing, this accuracy is not a luxury — it is a fundamental requirement that determines whether the process is viable at all.
Real-Time Error Correction Under Dynamic Loads
Industrial machines rarely operate under perfectly constant loads. A robotic arm changes its effective inertia as it extends and retracts. A conveyor system experiences sudden load spikes when products are placed on it. A spindle motor encounters varying cutting resistance as tool geometry changes. Servo motors and drives are engineered to handle these dynamics without losing positional integrity.
The servo drive's control algorithms — typically a combination of proportional, integral, and derivative (PID) control — calculate the necessary current output many thousands of times per second. This high update rate ensures that disturbances are corrected before they accumulate into meaningful positional errors. The result is smooth, stable motion even in mechanically demanding environments.
This real-time correction capability is one of the primary reasons servo motors and drives are preferred over open-loop alternatives in any application where load variability is expected. The system does not just execute a command — it verifies and enforces the outcome continuously throughout the motion profile.
Speed, Torque, and the Performance Envelope
High Torque Density at Variable Speeds
Servo motors and drives are designed to deliver high torque across a wide speed range, including at very low speeds where many other motor types struggle. This characteristic is critical in applications that require slow, controlled movement with high force — such as injection molding clamping mechanisms, precision grinding spindles, or tension control in web handling systems.
The torque-to-inertia ratio of a servo motor is typically much higher than that of a comparable induction motor. This means the motor can accelerate and decelerate rapidly without requiring an oversized frame. In high-cycle applications where axes must start, stop, and reverse hundreds of times per minute, this responsiveness directly translates into higher machine throughput and reduced cycle times.
Modern servo motors and drives also support torque control mode, where the drive regulates output torque rather than position or speed. This is particularly useful in assembly applications where a consistent clamping or pressing force must be maintained regardless of positional variation in the workpiece.
Smooth Velocity Profiles and Minimal Vibration
Precision automation is not only about reaching the right position — it is also about how the system gets there. Abrupt acceleration and deceleration create mechanical stress, vibration, and settling time that reduce both accuracy and machine longevity. Servo motors and drives address this through sophisticated motion profiling built into the drive firmware.
S-curve and trapezoidal velocity profiles allow the drive to ramp speed smoothly at the beginning and end of each move. This reduces the mechanical shock transmitted to the load and minimizes the time the system spends waiting for vibrations to dampen before the next operation can begin. In high-speed pick-and-place systems, for example, this directly affects how many cycles per minute the machine can reliably complete.
The combination of high torque density, wide speed range, and smooth motion profiling makes servo motors and drives the preferred choice whenever both speed and precision must coexist in the same application — a combination that is increasingly common as manufacturers push for higher output without sacrificing quality.
Integration with Modern Automation Architectures
Industrial Communication Protocols and Real-Time Networks
Contemporary automation systems are built around real-time communication networks that synchronize dozens or even hundreds of axes with microsecond-level timing. Servo motors and drives have evolved to participate natively in these architectures through support for industrial Ethernet protocols such as EtherCAT, PROFINET, EtherNet/IP, and MECHATROLINK.
EtherCAT, in particular, has become a dominant protocol in high-performance multi-axis systems because of its deterministic cycle times — often as low as 125 microseconds — and its ability to synchronize all connected drives to a single master clock. Servo motors and drives that support EtherCAT can participate in coordinated motion sequences where multiple axes must move in precise spatial and temporal relationship to one another, as required in five-axis machining centers or multi-robot welding cells.
This level of network integration means that servo motors and drives are not isolated components — they are active nodes in a digital automation ecosystem. Configuration, tuning, diagnostics, and firmware updates can all be performed over the network, reducing commissioning time and enabling remote maintenance capabilities that are increasingly valued in smart factory environments.
Compatibility with PLC and Motion Controller Ecosystems
Servo motors and drives are designed to work within the broader control hierarchy of a modern machine. They receive motion commands from PLCs, dedicated motion controllers, or PC-based control platforms and execute those commands with the precision and responsiveness that higher-level controllers depend on. The drive handles the low-level current and voltage regulation while the controller focuses on trajectory planning and process logic.
This division of responsibility is architecturally important. It allows machine builders to design systems where the control software is decoupled from the hardware-level motor management. Engineers can change motion profiles, update safety parameters, or reconfigure axis behavior through software without modifying the physical wiring or drive hardware. This flexibility accelerates both initial development and ongoing machine evolution.
The broad compatibility of servo motors and drives with standard automation platforms also reduces integration risk. When a drive supports widely adopted communication standards and follows established motion control conventions, it can be incorporated into existing machine architectures without requiring custom interface development or proprietary middleware.
Reliability, Safety, and Long-Term Operational Value
Built-In Protection and Fault Management
Precision automation environments demand not only accurate motion but also reliable, uninterrupted operation. Servo motors and drives incorporate multiple layers of protection to safeguard both the equipment and the process. Overcurrent protection, overvoltage and undervoltage detection, overtemperature monitoring, and encoder fault detection are standard features that prevent minor anomalies from escalating into costly failures.
When a fault condition is detected, the drive can execute a controlled stop rather than an abrupt power cut, protecting the mechanical components from shock loads and preserving the positional state of the system where possible. Fault codes are logged and can be retrieved via the communication network, giving maintenance teams the diagnostic information they need to identify root causes quickly and minimize downtime.
Many servo motors and drives also support functional safety standards such as SIL 2 or PLd, enabling safe torque off (STO) and safe stop functions that are required in collaborative robot applications and machinery subject to CE or UL safety certification. This built-in safety architecture simplifies compliance and reduces the need for external safety relays in many configurations.
Energy Efficiency and Regenerative Capabilities
Beyond performance, servo motors and drives offer meaningful energy efficiency advantages compared to traditional motor technologies. Because the drive precisely controls the current delivered to the motor at every moment, energy is consumed only as needed rather than being dissipated as heat in resistors or throttled through mechanical means. This efficiency is particularly significant in high-cycle applications where the motor is accelerating and decelerating continuously.
Many servo drives also support regenerative braking, where the kinetic energy of a decelerating load is converted back into electrical energy and either returned to the supply bus or shared with other drives on a common DC bus. In multi-axis systems, this energy sharing can substantially reduce peak power demand and overall energy consumption, contributing to both operating cost reduction and sustainability goals.
The long service life of quality servo motors and drives, combined with their low maintenance requirements — no brushes to replace, minimal mechanical wear due to smooth motion profiles — means that the total cost of ownership over a machine's operational life is often lower than alternatives that appear less expensive at the point of purchase.
FAQ
What makes servo motors and drives different from standard AC motors in automation?
Servo motors and drives operate as closed-loop systems, continuously monitoring actual position and velocity through encoder feedback and correcting any deviation in real time. Standard AC induction motors run open-loop, meaning they execute a command without verifying the outcome. This fundamental difference makes servo motors and drives far more suitable for applications requiring precise positioning, controlled acceleration, and consistent performance under variable loads.
How do servo motors and drives contribute to multi-axis synchronization?
When connected via real-time industrial Ethernet protocols such as EtherCAT, servo motors and drives can synchronize their motion to a shared master clock with microsecond-level precision. This allows multiple axes to execute coordinated trajectories simultaneously — essential in applications like robotic arms, gantry systems, and multi-spindle machining centers where spatial relationships between axes must be maintained throughout the motion cycle.
Are servo motors and drives suitable for low-speed, high-torque applications?
Yes. One of the key strengths of servo motors and drives is their ability to deliver rated torque across a wide speed range, including at very low speeds. This makes them well suited for applications such as tension control, slow-feed precision grinding, and assembly press operations where high force must be applied with fine positional control. The closed-loop torque control mode further enhances their suitability for force-sensitive processes.
What role does the encoder resolution play in the precision of servo motors and drives?
Encoder resolution directly determines how finely the drive can resolve the motor shaft position. A 17-bit absolute encoder, for example, provides over 131,000 counts per revolution, allowing the drive to detect and correct extremely small positional errors. Higher resolution also improves velocity smoothness at low speeds by providing more feedback updates per unit of shaft rotation. For applications with tight tolerances, selecting servo motors and drives with high-resolution encoders is a critical design decision.
Table of Contents
- The Closed-Loop Advantage That Defines Precision
- Speed, Torque, and the Performance Envelope
- Integration with Modern Automation Architectures
- Reliability, Safety, and Long-Term Operational Value
-
FAQ
- What makes servo motors and drives different from standard AC motors in automation?
- How do servo motors and drives contribute to multi-axis synchronization?
- Are servo motors and drives suitable for low-speed, high-torque applications?
- What role does the encoder resolution play in the precision of servo motors and drives?